

Solutions · Medical & healthcare
Simulation for robots that work next to people
Surgical and rehabilitation robots, lab automation and imaging pipelines need evidence long before a patient is involved. EsaSim runs large, reproducible simulation studies on anatomy, devices and workflows, and keeps the record of every run.
What EsaSim answers
The questions EsaSim answers for medical device teams
Evidence is needed long before a patient is involved. These are the questions reproducible simulation studies answer, with every run on record.
Does the instrument stay within safe force and clearance across anatomies?
Sweep instrument paths and camera views over anatomy variations, and record contact forces and clearances per run, so the worst cases are known and replayable.
Does our segmentation hold on scans unlike the training set?
Generate synthetic views from anatomical models to stress segmentation and registration on the shapes and contrasts the training set lacks.
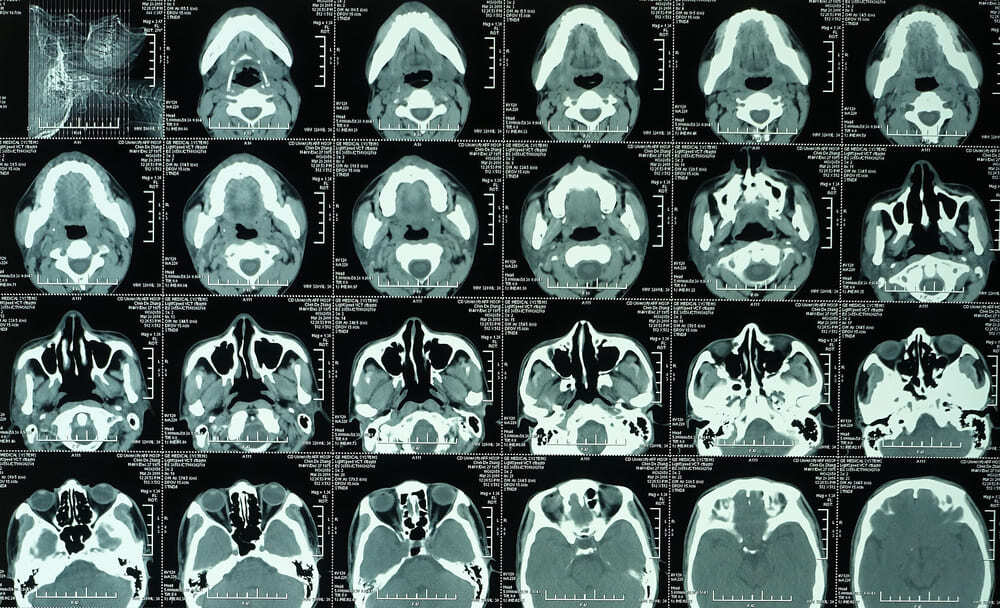
Can a CT scan become a 3D model we can turn, cut and print?
Read the scan, turn each labelled structure into a closed, coloured surface, and print it as STL. For research, teaching and demos, not for clinical use.
CT to 3D anatomyWill the exoskeleton controller work for different bodies and gaits?
Sweep body sizes, masses and gait patterns against the controller, and see where assistance becomes too much, too little or too late.
Can we show exactly what ran, for the verification file?
Each run keeps its spec, versions, hardware and outputs, and scans stay on your own workers. Sealed evidence records are in development.
Run evidenceTypical workloads
Surgical robotics
Instrument motion, tissue contact and camera views swept over anatomy variations.
Medical imaging
Synthetic CT and MRI views from anatomical models to stress-test segmentation and registration.
Rehabilitation and assistive devices
Exoskeleton and prosthesis control across body sizes and gaits.
Lab and pharmacy automation
Pick-and-place of tubes, vials and plates in crowded benches.
Available now
From a CT scan to anatomy you can move
Three blocks run on any worker, on the CPU. Scans stay on your workers; only the 3D scene, previews and tables reach EsaSim. For research, teaching and demos, not for clinical use.
Read medical images
CT and MR scans in NIfTI, NRRD, MHA or DICOM, checked for spacing, orientation and missing slices, with three slices of each and no patient data in the tables.
Labels to 3D models
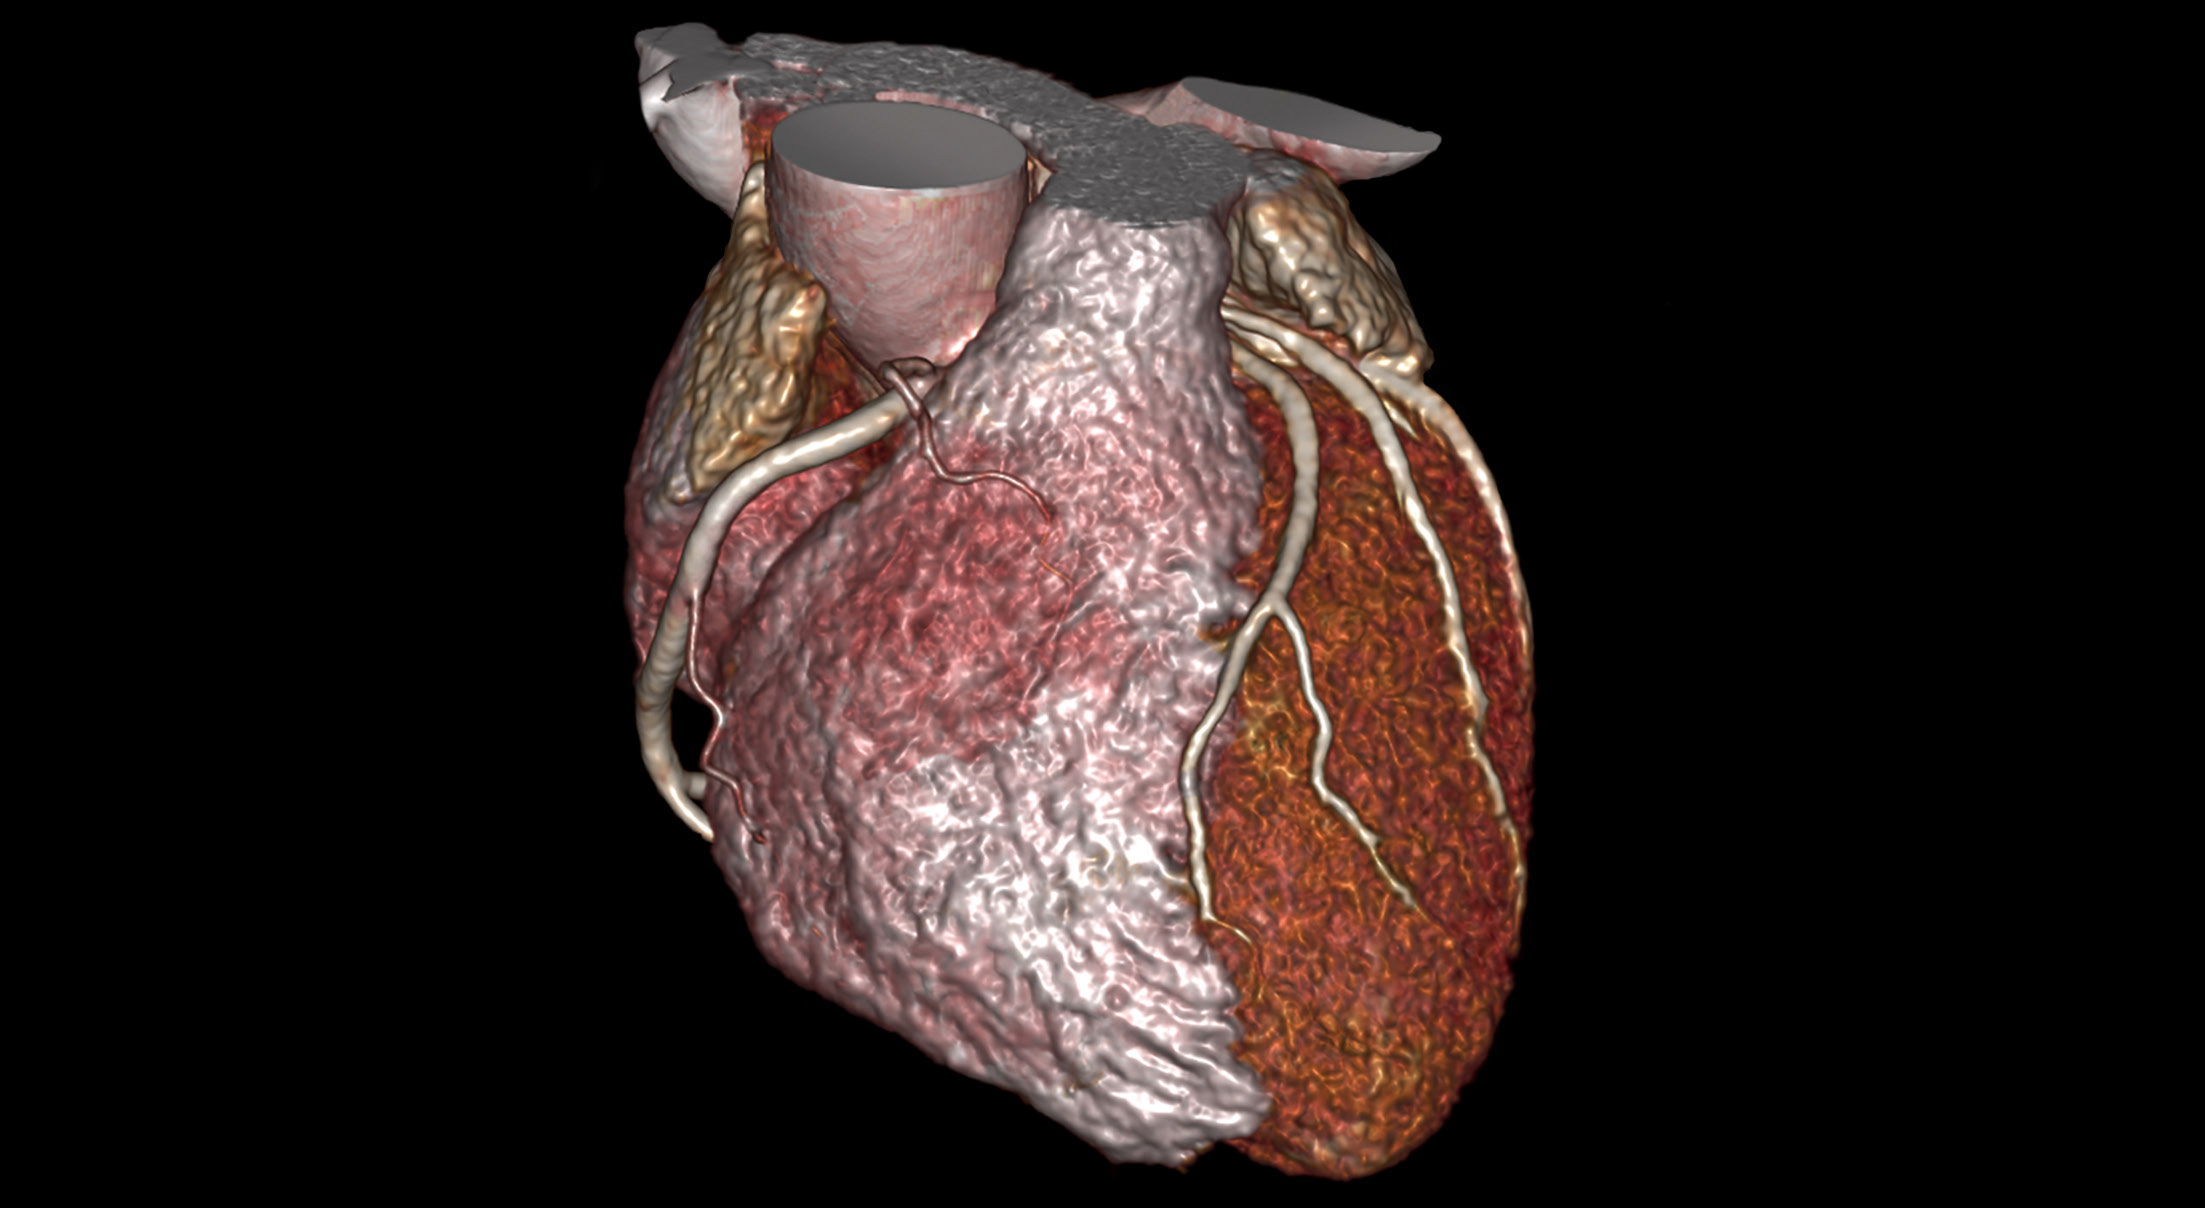
Each segmented structure becomes a smoothed, closed surface: a coloured scene for the 3D view and STL files ready to print, checked for watertightness.
Soft body model
Organs filled with spheres joined by elastic links, with stiffness measured per tissue: turn the body and they sag, sway and can be pulled.
Every run traceable
Each run keeps its flow version, the data it read, hardware and outputs, which is the raw material for verification and validation records. Data stays on your own servers; nothing is uploaded unless you choose to.
Bring your device team on board
We can walk you through a sweep on your own anatomy models.